Memetic Algorithm-Based Path Generation for Multiple Dubins Vehicles Performing Remote Tasks
Doo-Hyun Cho, Han‐Lim Choi
Abstract
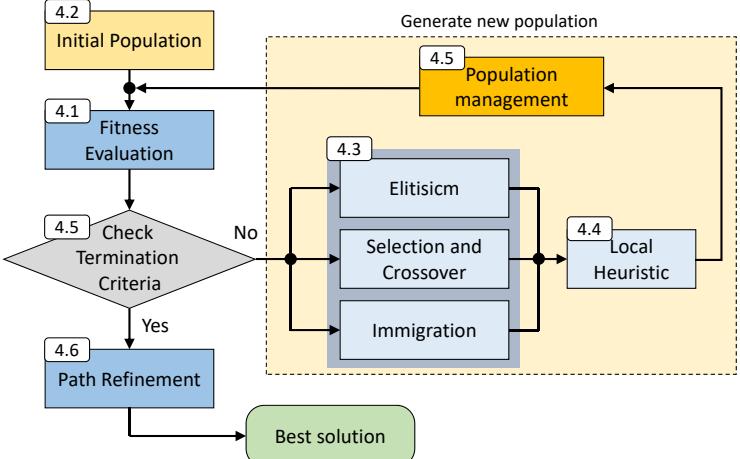
This paper formalizes path planning problem for a group of heterogeneous Dubins vehicles performing tasks in a remote fashion and develops a memetic algorithm-based method to effectively produce the paths. In the setting, the vehicles are initially located at multiple depots in a twodimensional space and the objective of planning is to minimize a weighted sum of the total tour cost of the group and the largest individual tour cost amongst the vehicles. While the presented formulation takes the form of a mixed-integer linear program (MILP) for which off-the-shelf solvers are available, the MILP solver easily loses the tractability as the number of tasks and agents grow. Therefore, a memetic algorithm tailored to the presented formulation is proposed. The algorithm features a sophisticated encoding scheme to efficiently. In addition, a path refinement technique that optimizes on the detailed tours with the sequence of visits fixed is proposed to finally obtain further optimized trajectories. Comparative numerical experiments show the validity and efficiency of the proposed methods compared with the previous methods in the literature.
§ The Valyu brief
Reading the full paper and taking notes. This takes a few seconds…
§ Ask this paper
Ask a question about this paper
Valyu reads the full text and answers from what the paper actually says.
Searching the other archives…