A Group Consensus-Driven Auction Algorithm for Cooperative Task Allocation Among Heterogeneous Multi-Agents
Gang Wang, Hongfang Han, Xiaowei Liu, Hanfeng Jiang, Ming Zhang
Abstract
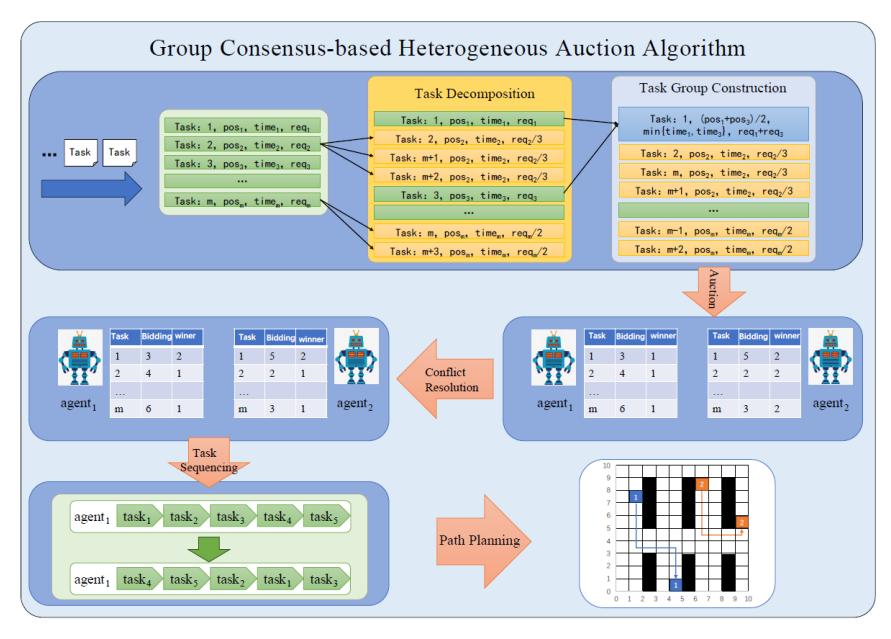
— In scenarios like automated warehouses, assigning tasks to robots presents a heterogeneous multitask and multi-agent task allocation problem. However, existing task allocation study ignores the integration of multi-task and multi-attribute agent task allocation with heterogeneous task allocation. In addition, current algorithms are limited by scenario constraints and can incur significant errors in specific contexts. Therefore, this study proposes a distributed heterogeneous multi-task and multiagent task allocation algorithm with a time window, called group consensus-based heterogeneous auction (GCBHA). Firstly, this method decomposes tasks that exceed the capability of a single Agent into subtasks that can be completed by multiple independent agents. And then groups similar or adjacent tasks through a heuristic clustering method to reduce the time required to reach a consensus. Subsequently, the task groups are allocated to agents that meet the conditions through an auction process. Furthermore, the method evaluates the task path cost distance based on the scenario, which can calculate the task cost more accurately. The experimental results demonstrate that GCBHA performs well in terms of task allocation time and solution quality, with a significant reduction in the error rate between predicted task costs and actual costs.
§ The Valyu brief
Reading the full paper and taking notes. This takes a few seconds…
§ Ask this paper
Ask a question about this paper
Valyu reads the full text and answers from what the paper actually says.
Searching the other archives…