JoyAI-RA 0.1: A Foundation Model for Robotic Autonomy
Tianle Zhang, Zhihao Yuan, Dafeng Chi, Peidong Liu, Dongwei Li, Kejun Hu, Likui Zhang, Junnan Nie, Ziming Wei, Zengjue Chen, Yili Tang, Jiayi Li, Zhiyuan Xiang, Mingyang Li, Tianci Luo, Hanwen Wan, Ao Li, Linbo Zhai, Zhihao Zhan, Yuzheng Zhuang, Liang Lin, Xiaodong Bai, Jiakun Cai, Peng Cao, Kangliang Chen, Siang Chen, Yixiang Dai, Shuai Di, Nan Duan, Yicheng Gong, Chenguang Gui, Yucheng Guo, Peng Hao, Qingrong He, Haoyang Huang, Kunrui Huang, Zhixuan Huang, Shibo Jin, Yixiang Jin, Anson Li, Dongjiang Li, Jiawei Li, Ruodai Li, Yihang Li, Yuzhen Li, Jiaming Liang, Fangsheng Liu, Jing Long, Mingxi Luo, Xing Pan, Hui Shen, Xiaomeng Tian, Daming Wang, Song Wang, Junwu Xiong, Hang Xu, Wanting Xu, Zhengcheng Yu, He Zhang, Jiyao Zhang, Lin Zhao, Chen Zhou
Abstract
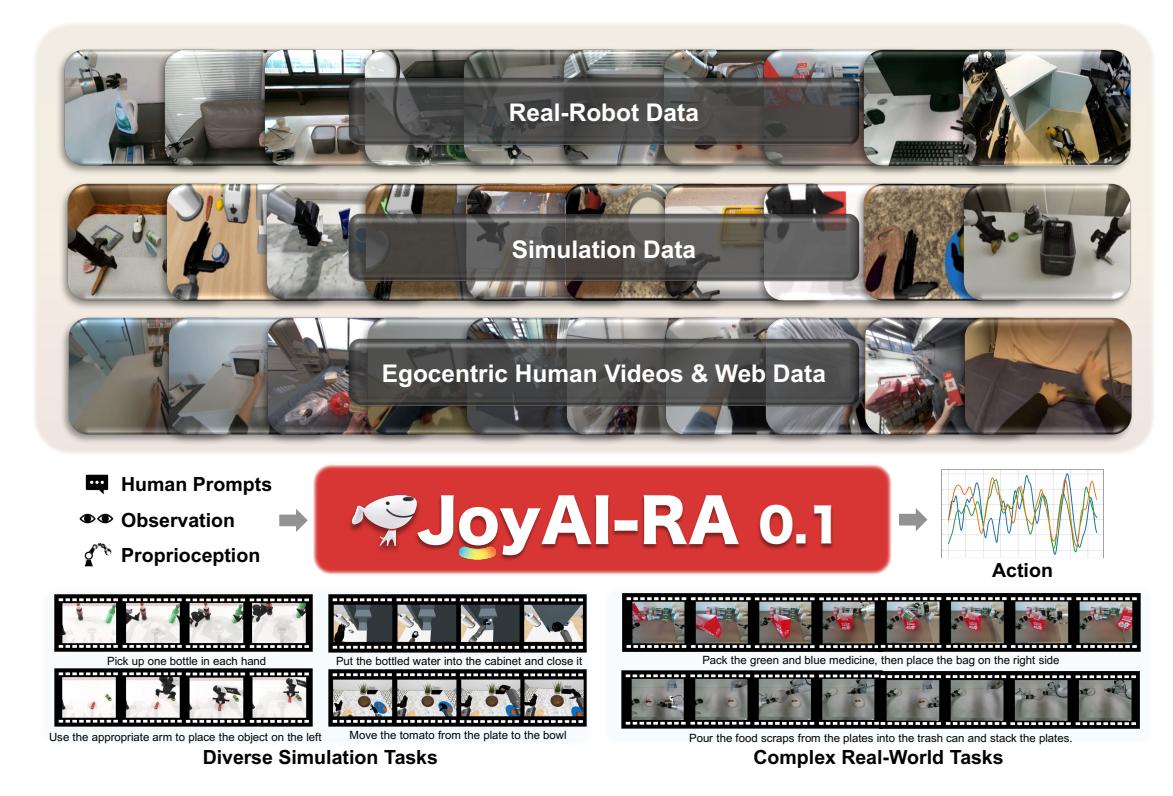
Robotic autonomy in open-world environments is fundamentally limited by insufficient data diversity and poor cross-embodiment generalization. Existing robotic datasets are often limited in scale and task coverage, while relatively large differences across robot embodiments impede effective behavior knowledge transfer. To address these challenges, we propose JoyAI-RA, a vision-language-action (VLA) embodied foundation model tailored for generalizable robotic manipulation. JoyAI-RA presents a multi-source multi-level pretraining framework that integrates web data, large-scale egocentric human manipulation videos, simulation-generated trajectories, and real-robot data. Through training on heterogeneous multi-source data with explicit action-space unification, JoyAI-RA effectively bridges embodiment gaps, particularly between human manipulation and robotic control, thereby enhancing cross-embodiment behavior learning. JoyAI-RA outperforms state-of-the-art methods in both simulation and real-world benchmarks, especially on diverse tasks with generalization demands.
§ The Valyu brief
Reading the full paper and taking notes. This takes a few seconds…
§ Ask this paper
Ask a question about this paper
Valyu reads the full text and answers from what the paper actually says.
Searching the other archives…