Nonvisual Classification of Ground-Condition by Artificial Proprioception in an Amoeba-Inspired Autonomous Walking Robot
Hyoto Yamaguchi, Zenji Yatabe, Seiya Kasai
Abstract
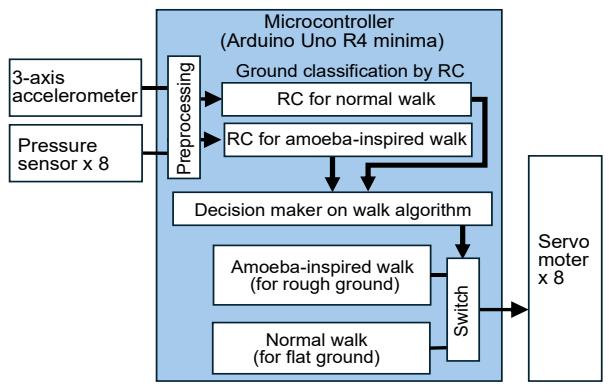
Nonvisual classification of ground condition based on a multimodal sensing approach was investigated for an amoeba-inspired autonomous walking robot. To classify ground condition without image sensing and processing, we implemented artificial proprioception by integrating a three-axis accelerometer, eight foot pressure sensors, and reservoir computing (RC). Even when large fluctuations in the sensor outputs are caused by dynamic motions of a four-legged robot in walking, our system can classify the ground condition, flat or rough, with high accuracy. We demonstrate on-site switching of walking gait depending on ground condition in the robot. We also discuss the contribution of each sensor to ground condition classification.
§ The Valyu brief
Reading the full paper and taking notes. This takes a few seconds…
§ Ask this paper
Ask a question about this paper
Valyu reads the full text and answers from what the paper actually says.
Searching the other archives…