VP-SOM: View-Planning Method for Indoor Active Sparse Object Mapping Based on Information Abundance and Observation Continuity
Jiadong Zhang, Wei Wang, Yingbai Hu, Chao Zeng, Alois Christian Knoll, Shu Li
Abstract
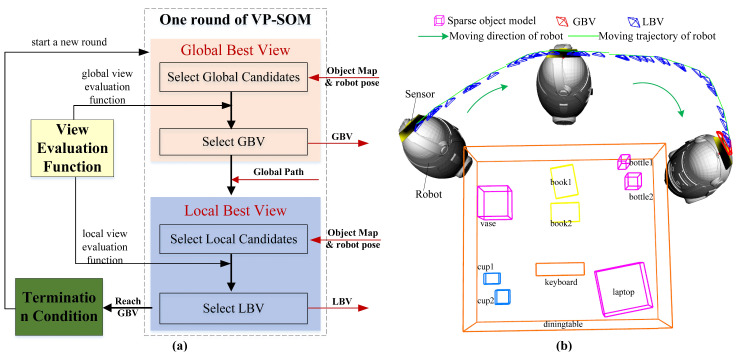
'Alois Christian Knoll' 'Shu Li'] Active mapping is an important technique for mobile robots to autonomously explore and recognize indoor environments. View planning, as the core of active mapping, determines the quality of the map and the efficiency of exploration. However, most current view-planning methods focus on low-level geometric information like point clouds and neglect the indoor objects that are important for human-robot interaction. We propose a novel View-Planning method for indoor active Sparse Object Mapping (VP-SOM). VP-SOM takes into account for the first time the properties of object clusters in the coexisting human-robot environment. We categorized the views into global views and local views based on the object cluster, to balance the efficiency of exploration and the mapping accuracy. We developed a new view-evaluation function based on objects’ information abundance and observation continuity, to select the Next-Best View (NBV). Especially for calculating the uncertainty of the sparse object model, we built the object surface occupancy probability map. Our experimental results demonstrated that our view-planning method can explore the indoor environments and build object maps more accurately, efficiently, and robustly.
§ The Valyu brief
Reading the full paper and taking notes. This takes a few seconds…
§ Ask this paper
Ask a question about this paper
Valyu reads the full text and answers from what the paper actually says.
Searching the other archives…