Research on a Particle Filtering Multi-Target Tracking Algorithm for Distributed Systems
Bing Han, Zilong Ge, Zhigang Su, Jingtang Hao, Yin Zhang, Yulin Huang, Deqing Mao, Yanki Aslan
Abstract
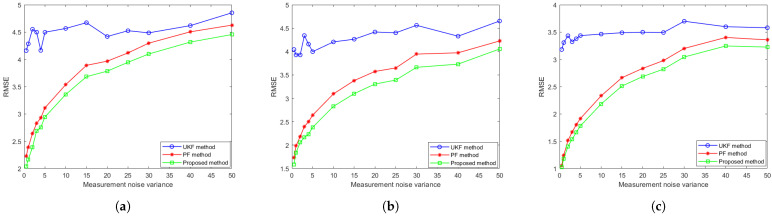
The growth of unmanned aerial vehicle applications in the low-altitude economy demand advanced multi-target tracking systems. Unlike traditional approaches that assume independent measurements, distributed systems generate coupled measurements containing additional target relationship information. This paper proposes a novel distributed particle filtering algorithm through introducing the coupled measurement into the conventional particle filtering method. In the proposed method, we fuse direct and coupled measurements via optimization and then build a cost function to optimize the particle weights. Comparative evaluations across motion models, noise levels, and the number of targets demonstrate the outperforming performance of the proposed method compared to conventional particle filtering and the unscented Kalman filtering algorithm, with more than 7% accuracy improvement over baselines. The results prove particular robustness to measurement noise and the increasing number of targets.
§ The Valyu brief
Reading the full paper and taking notes. This takes a few seconds…
§ Ask this paper
Ask a question about this paper
Valyu reads the full text and answers from what the paper actually says.
Searching the other archives…