Robust Visuomotor Control for Humanoid Loco-Manipulation Using Hybrid Reinforcement Learning
Chenzheng Wang, Qiang Huang, Xuechao Chen, Zeyu Zhang, Jing Shi, Pengcheng Liu, Qinbing Fu, Tiong Hoo Lim
Abstract
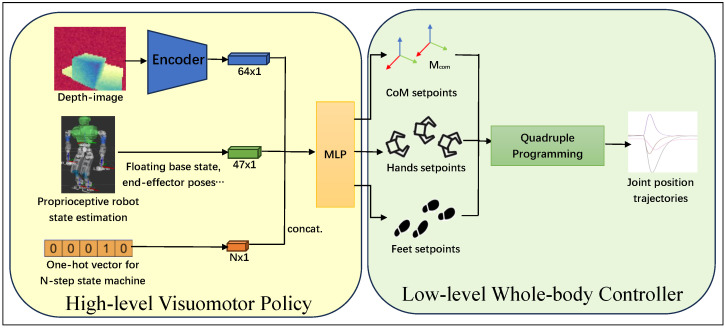
'Pengcheng Liu' 'Qinbing Fu' 'Tiong Hoo Lim'] Loco-manipulation tasks using humanoid robots have great practical value in various scenarios. While reinforcement learning (RL) has become a powerful tool for versatile and robust whole-body humanoid control, visuomotor control in loco-manipulation tasks with RL remains a great challenge due to their high dimensionality and long-horizon exploration issues. In this paper, we propose a loco-manipulation control framework for humanoid robots that utilizes model-free RL upon model-based control in the robot’s tasks space. It implements a visuomotor policy with depth-image input, and uses mid-way initialization and prioritized experience sampling to accelerate policy convergence. The proposed method is validated on typical loco-manipulation tasks of load carrying and door opening resulting in an overall success rate of 83%, where our framework automatically adjusts the robot motion in reaction to changes in the environment.
§ The Valyu brief
Reading the full paper and taking notes. This takes a few seconds…
§ Ask this paper
Ask a question about this paper
Valyu reads the full text and answers from what the paper actually says.
Searching the other archives…