Numerical Investigation of Halbach-Array-Based Flexible Magnetic Sensors for Wide-Range Deformation Detection
Yina Han, Shuaiqi Zhang, Chenglin Wen, Jie Han, Wenbin Kang, Zhiqiang Zheng, Chamil Abeykoon
Abstract
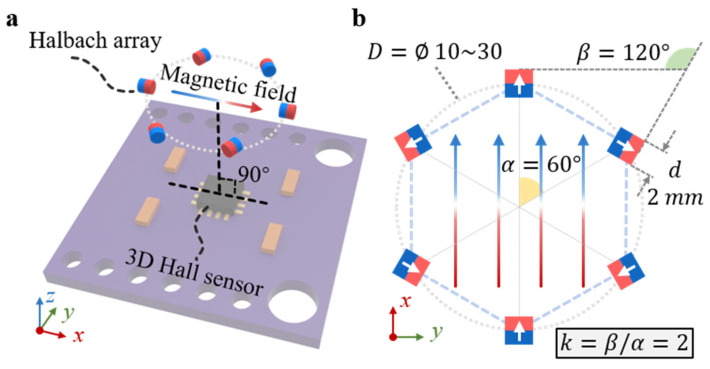
Highlights A Halbach-array-based magnetic tactile sensor is proposed, where the soft magnetic layer is decoupled from the rigid Hall sensing unit to achieve wide-range, high-sensitivity and remote strain detection. Finite element simulations show that the Halbach configuration strengthens and homogenizes the magnetic field while reducing its spatial dimensionality, enabling simplified data processing, faster response, and scalable design for next-generation flexible tactile sensing in wearable and robotic applications. What are the main findings?1. Decoupled architecture for enhanced magnetic coupling. Separating the flexible PDMS-based Halbach magnetic array from the fixed Hall sensor preserves field uniformity under large deformation and enables mT-level detection at a sensing distance up to 15 mm. 2. Dimensionality reduction of magnetic field distribution. The Halbach configuration transforms a complex 3D magnetic field into a near 1D directional field, enhancing sensitivity, simplifying signal processing, and supporting scalable high-resolution tactile sensing. What are the implication of the main findings?1. The decoupled Halbach-array design provides a general strategy for achieving wide-range, high-sensitivity magnetic sensing in flexible systems, enabling more reliable tactile perception in wearable and robotic applications. 2. The dimensionality reduction of magnetic fields offers a new approach to simplify signal processing and enhance real-time sensing speed in future intelligent tactile interfaces. Abstract Flexible magnetic tactile sensors hold great promise for wearable electronics and intelligent robotics but often suffer from limited strain range and complex magnetic field variations due to rigid-soft coupling between the Hall sensor and magnetic layer. In this study, we propose a Halbach-array-based magnetic tactile sensor that structurally decouples the soft magnetic deformation layer from the rigid Hall sensing unit. The sensor embeds k = 2 Halbach-configured magnetic cubes within a PDMS matrix, while the Hall element is fixed at a remote, rigid location.
§ The Valyu brief
Reading the full paper and taking notes. This takes a few seconds…
§ Ask this paper
Ask a question about this paper
Valyu reads the full text and answers from what the paper actually says.
Searching the other archives…