Solving robotics tasks with prior demonstration via exploration-efficient deep reinforcement learning Shen and Sloth 10.3389/frobt.2025.1682200
Chengyandan Shen, Christoffer Sloth
Abstract
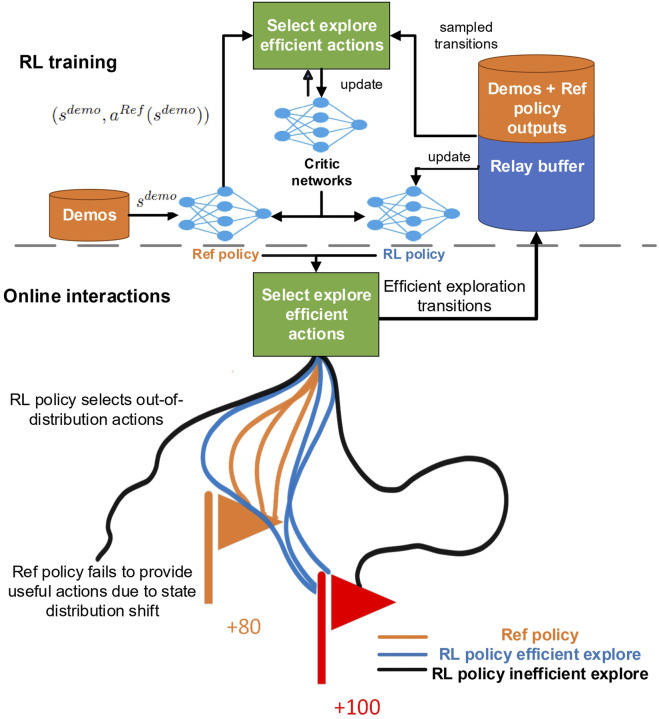
This paper proposes an exploration-efficient deep reinforcement learning with reference (DRLR) policy framework for learning robotics tasks incorporating demonstrations. The DRLR framework is developed based on an imitation bootstrapped reinforcement learning (IBRL) algorithm. Here, we propose to improve IBRL by modifying the action selection module. The proposed action selection module provides a calibrated Q-value, which mitigates the bootstrapping error that otherwise leads to inefficient exploration. Furthermore, to prevent the reinforcement learning (RL) policy from converging to a sub-optimal policy, soft actor-critic (SAC) is used as the RL policy instead of twin delayed DDPG (TD3). The effectiveness of our method in mitigating the bootstrapping error and preventing overfitting is empirically validated by learning two robotics tasks: bucket loading and open drawer, which require extensive interactions with the environment. Simulation results also demonstrate the robustness of the DRLR framework across tasks with both low and high state-action dimensions and varying demonstration qualities. To evaluate the developed framework on a real-world industrial robotics task, the bucket loading task is deployed on a real wheel loader. The sim-to-real results validate the successful deployment of the DRLR framework.
§ The Valyu brief
Reading the full paper and taking notes. This takes a few seconds…
§ Ask this paper
Ask a question about this paper
Valyu reads the full text and answers from what the paper actually says.
Searching the other archives…