A New Multidimensional Repulsive Potential Field to Avoid Obstacles by Nonholonomic UAVs in Dynamic Environments
Cezary Kownacki, Leszek Ambroziak, Arturo de la Escalera Hueso
Abstract
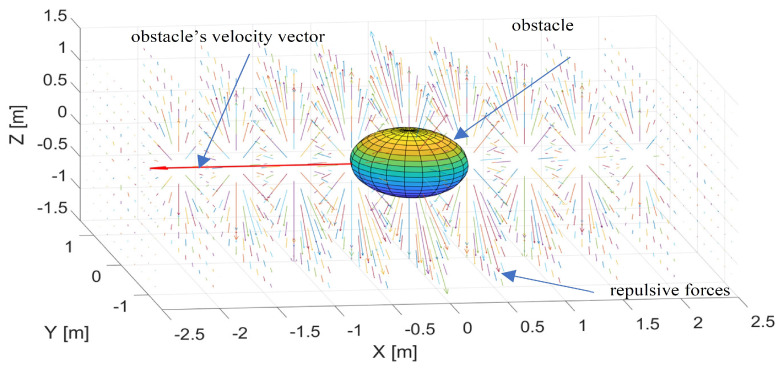
The ability of autonomous flight with obstacle avoidance should be a fundamental feature of all modern unmanned aerial vehicles (UAVs). The complexity and difficulty of such a task, however, significantly increase in cases combining moving obstacles and nonholonomic UAVs. Additionally, since they assume the symmetrical distribution of repulsive forces around obstacles, traditional repulsive potential fields are not well suited for nonholonomic vehicles. The limited maneuverability of these types of UAVs, including fixed-wing aircraft, requires consideration not only of their relative position, but also their speed as well as the direction in which the obstacles are moving. To address this issue, the following work presents a novel multidimensional repulsive potential field dedicated to nonholonomic UAVs. This field generates forces that repulse the UAV not from the obstacle’s geometrical center, but from areas immediately behind and in front of it located along a line defined by the obstacle’s velocity vector. The strength of the repulsive force depends on the UAV’s distance to the line representing the obstacle’s movement direction, distance to the obstacle along that line, and the relative speed between the UAV and the obstacle projected to the line, making the proposed repulsive potential field multidimensional. Numerical simulations presented within the paper prove the effectiveness of the proposed novel repulsive potential field in controlling the flight of nonholonomic UAVs.
§ The Valyu brief
Reading the full paper and taking notes. This takes a few seconds…
§ Ask this paper
Ask a question about this paper
Valyu reads the full text and answers from what the paper actually says.
Searching the other archives…