Safe Robot Trajectory Control Using Probabilistic Movement Primitives and Control Barrier Functions Davoodi et al. Safe Robot Trajectory Control
Mohammadreza Davoodi, Asif Iqbal, Joseph M. Cloud, William J. Beksi, Nicholas R. Gans
Abstract
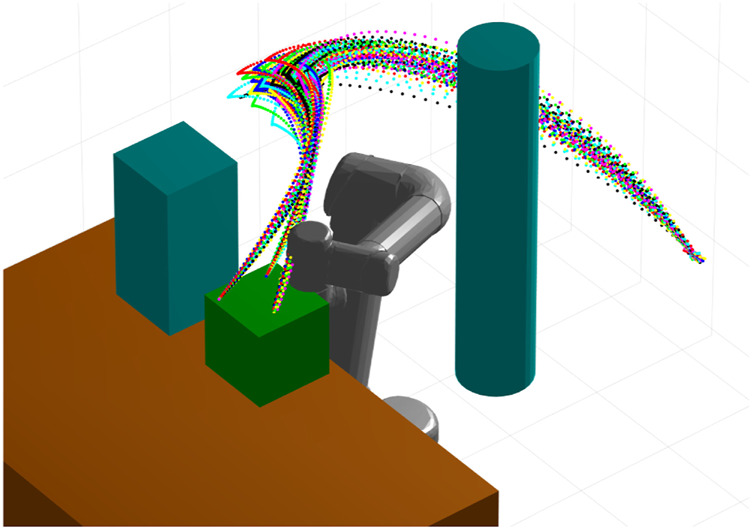
'Nicholas R. Gans'] In this paper, we present a novel means of control design for probabilistic movement primitives (ProMPs). Our proposed approach makes use of control barrier functions and control Lyapunov functions defined by a ProMP distribution. Thus, a robot may move along a trajectory within the distribution while guaranteeing that the system state never leaves more than a desired distance from the distribution mean. The control employs feedback linearization to handle nonlinearities in the system dynamics and real-time quadratic programming to ensure a solution exists that satisfies all safety constraints while minimizing control effort. Furthermore, we highlight how the proposed method may allow a designer to emphasize certain safety objectives that are more important than the others. A series of simulations and experiments demonstrate the efficacy of our approach and show it can run in real time.
§ The Valyu brief
Reading the full paper and taking notes. This takes a few seconds…
§ Ask this paper
Ask a question about this paper
Valyu reads the full text and answers from what the paper actually says.
Searching the other archives…